Building the platform
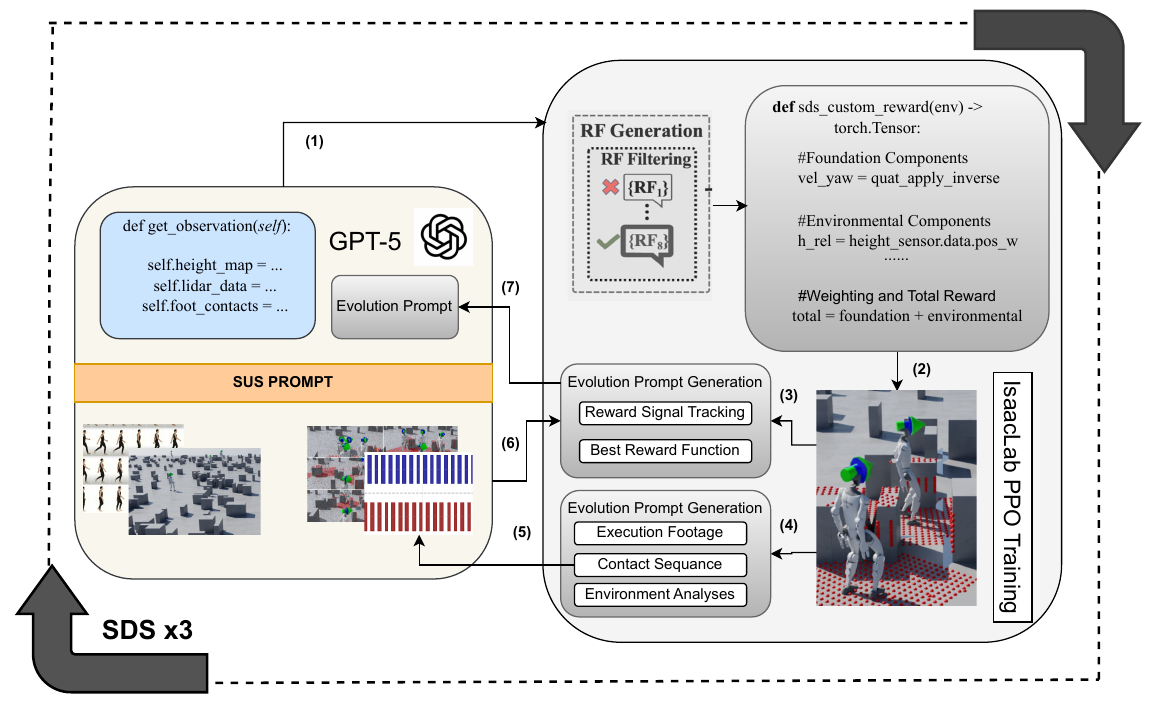
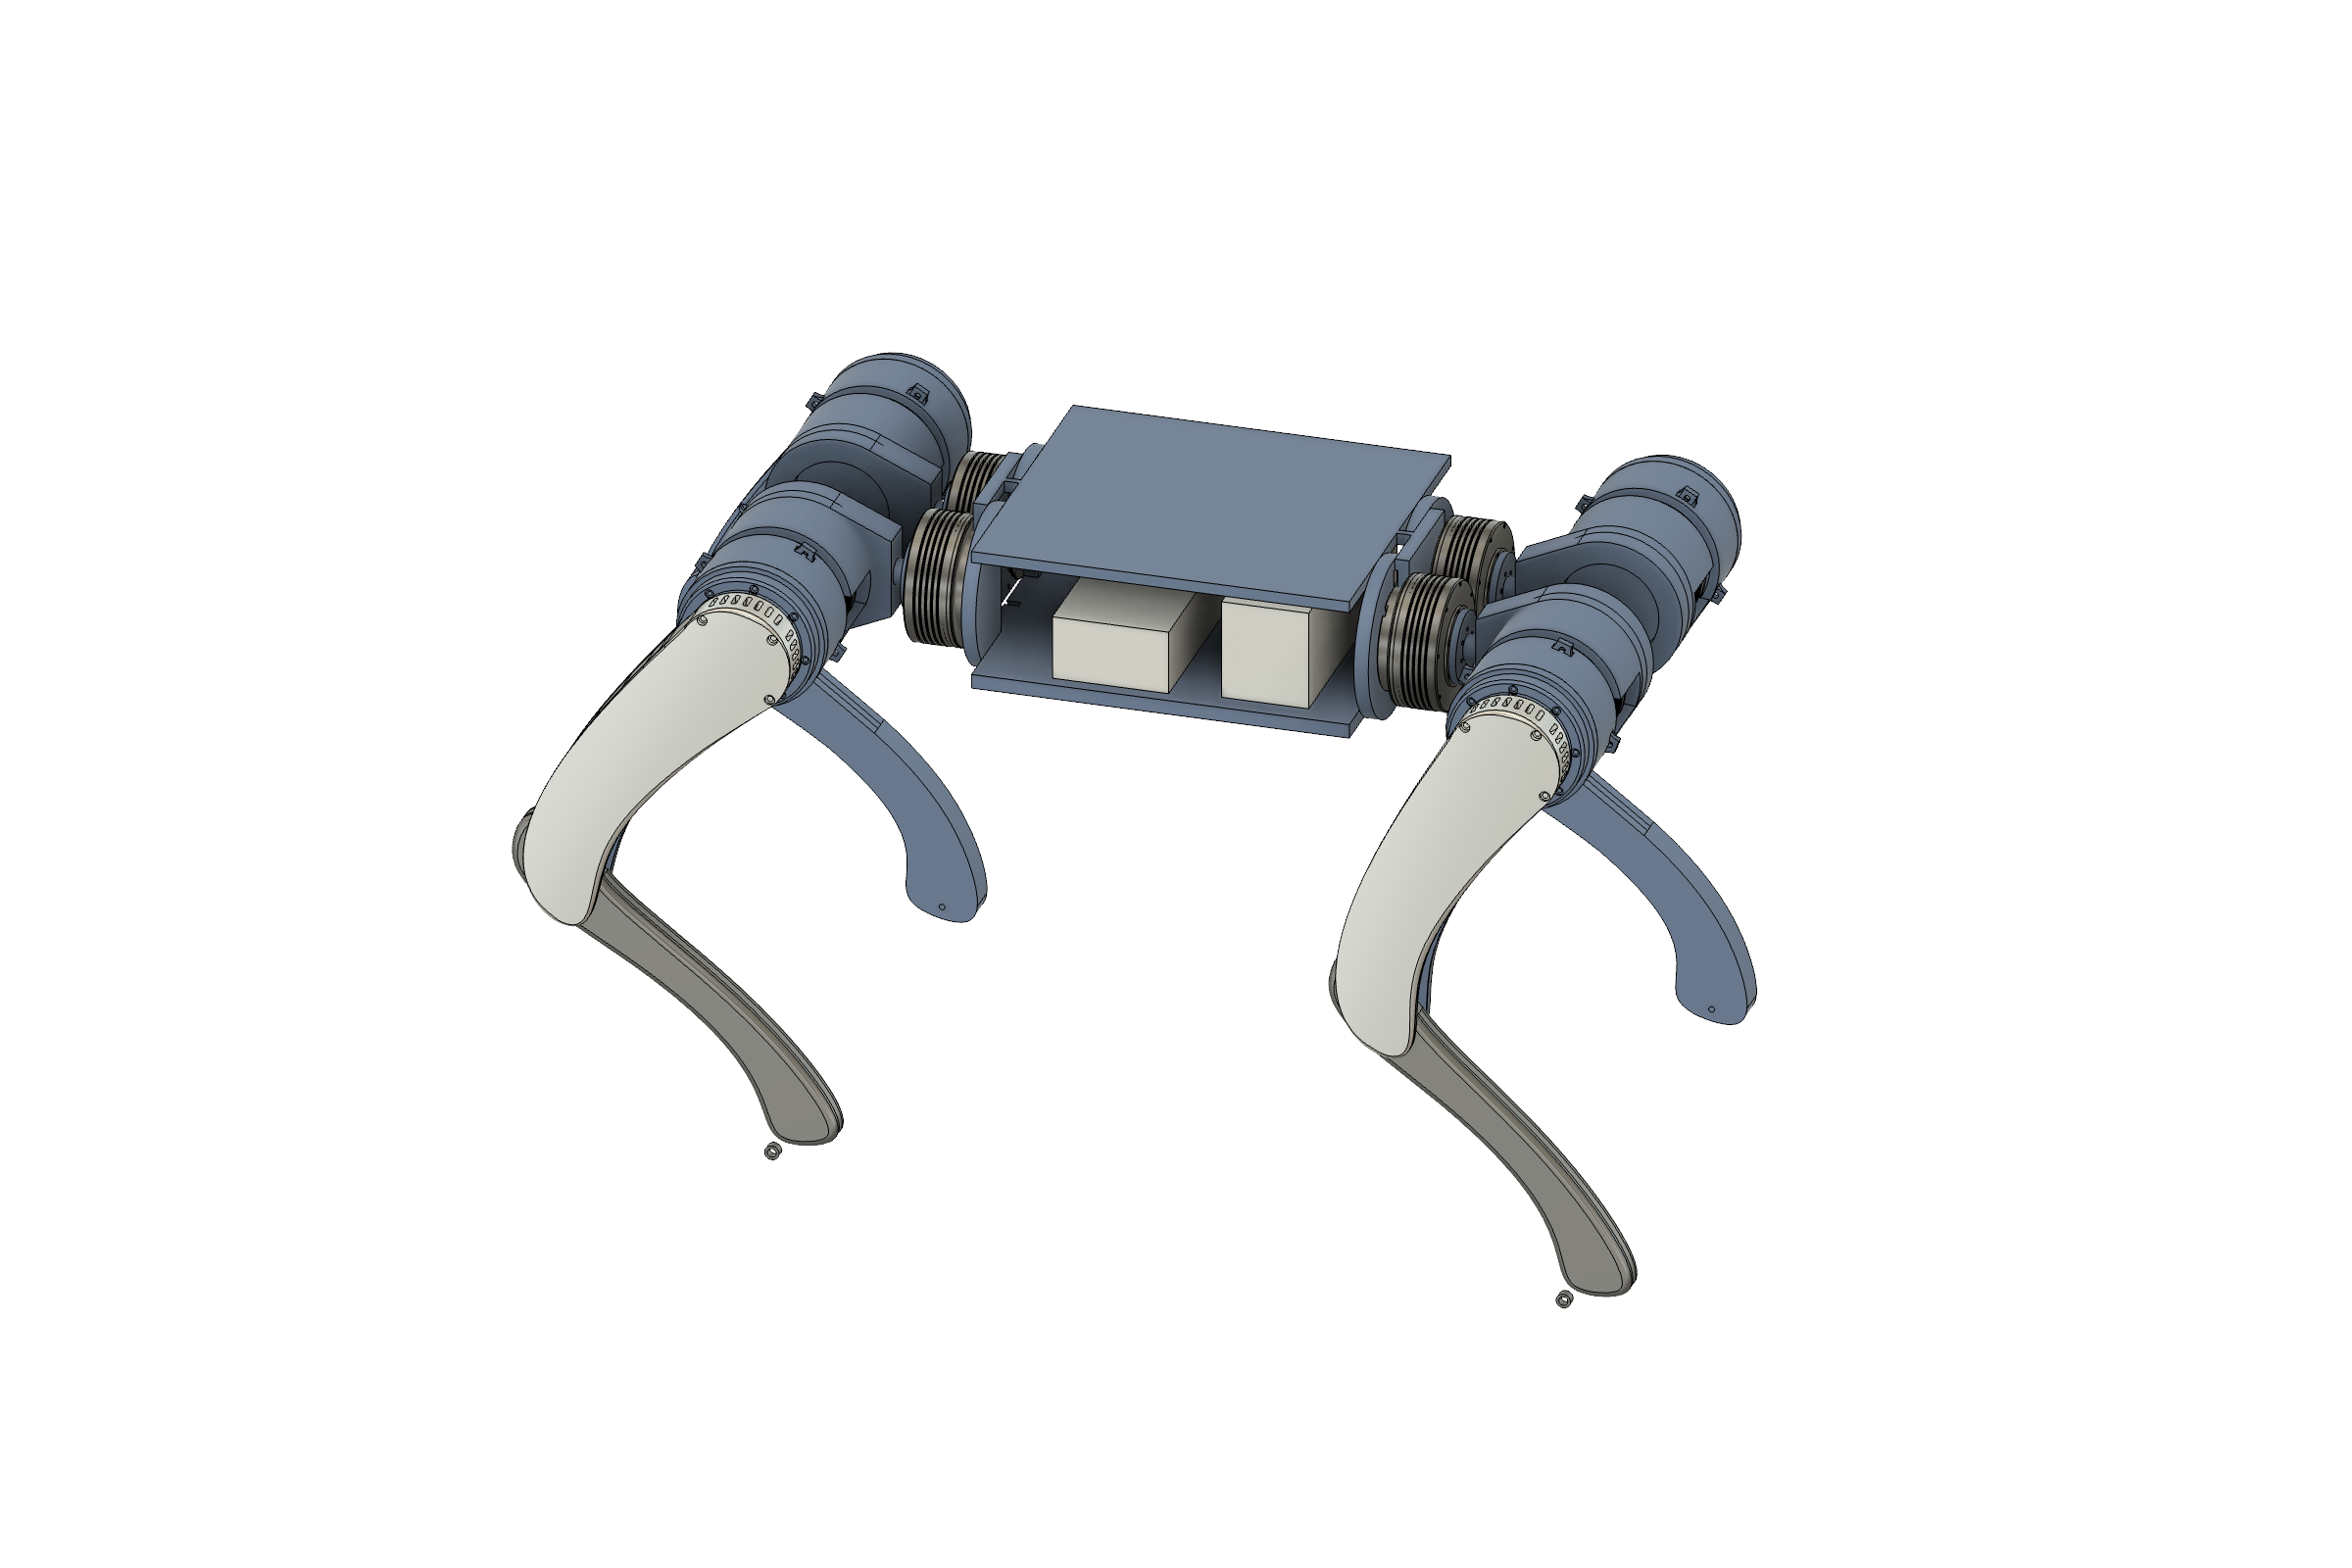
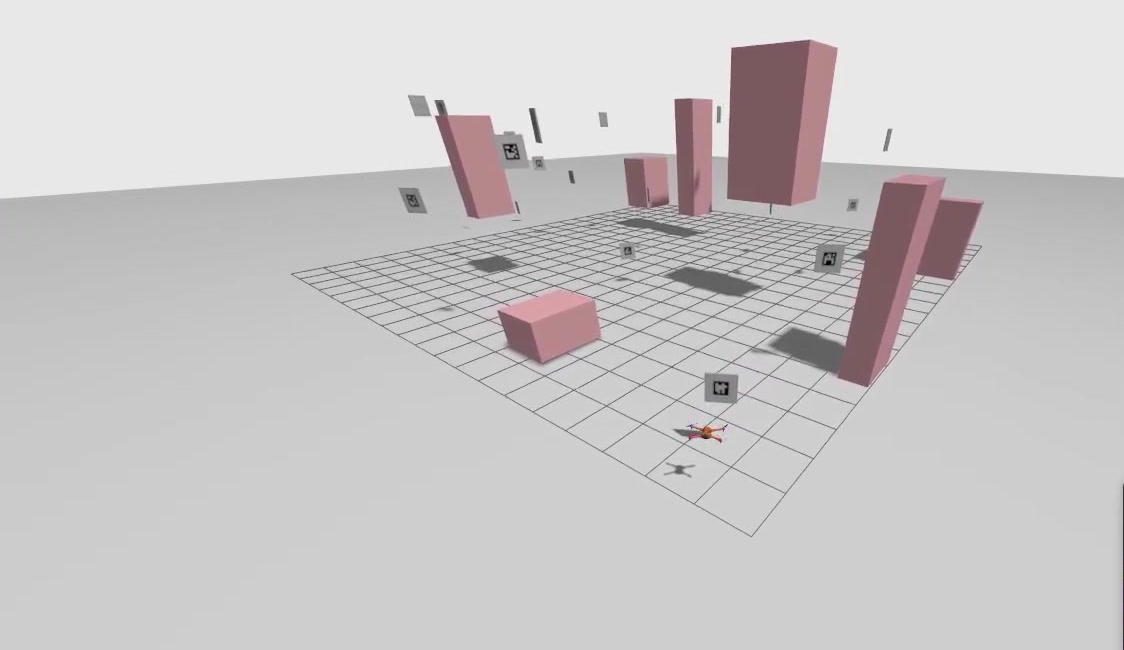
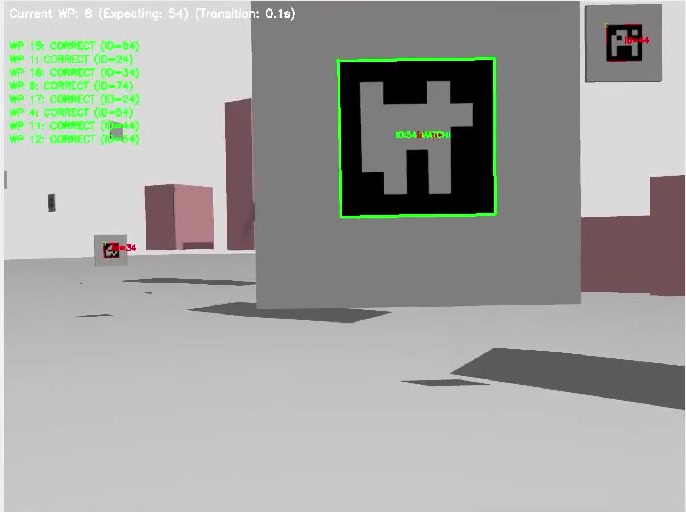
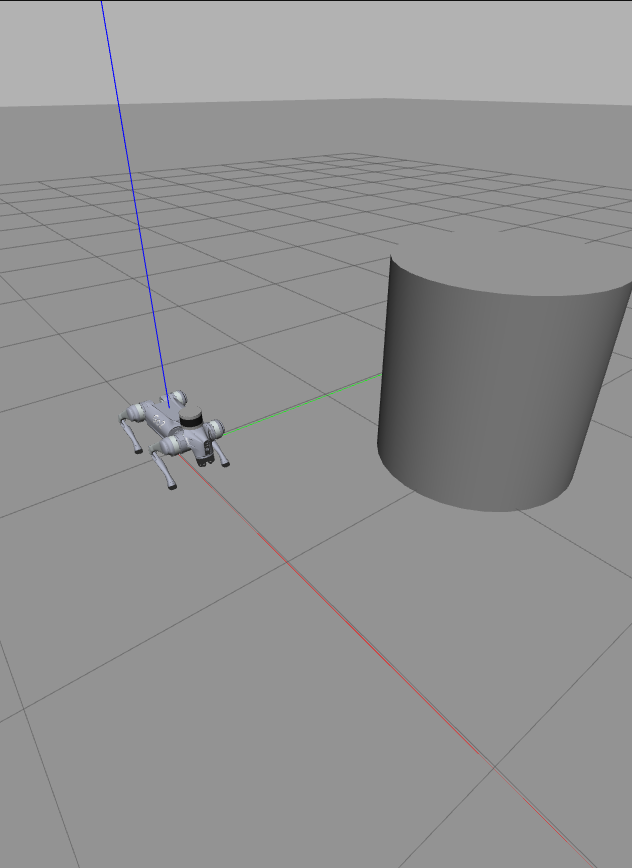
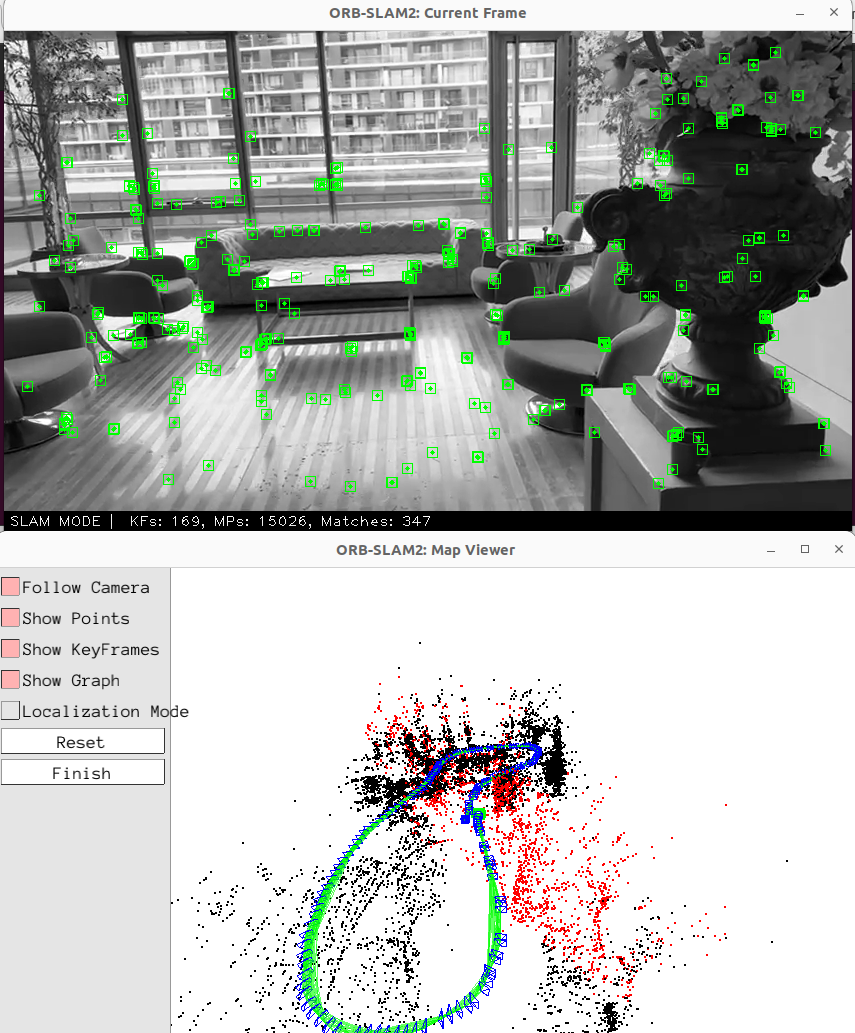
I am developing the platform across mechanical design, embedded electronics, communication and control software. The current work focuses on simulation validation and hardware integration.
CONTROL AND ESTIMATION STACK
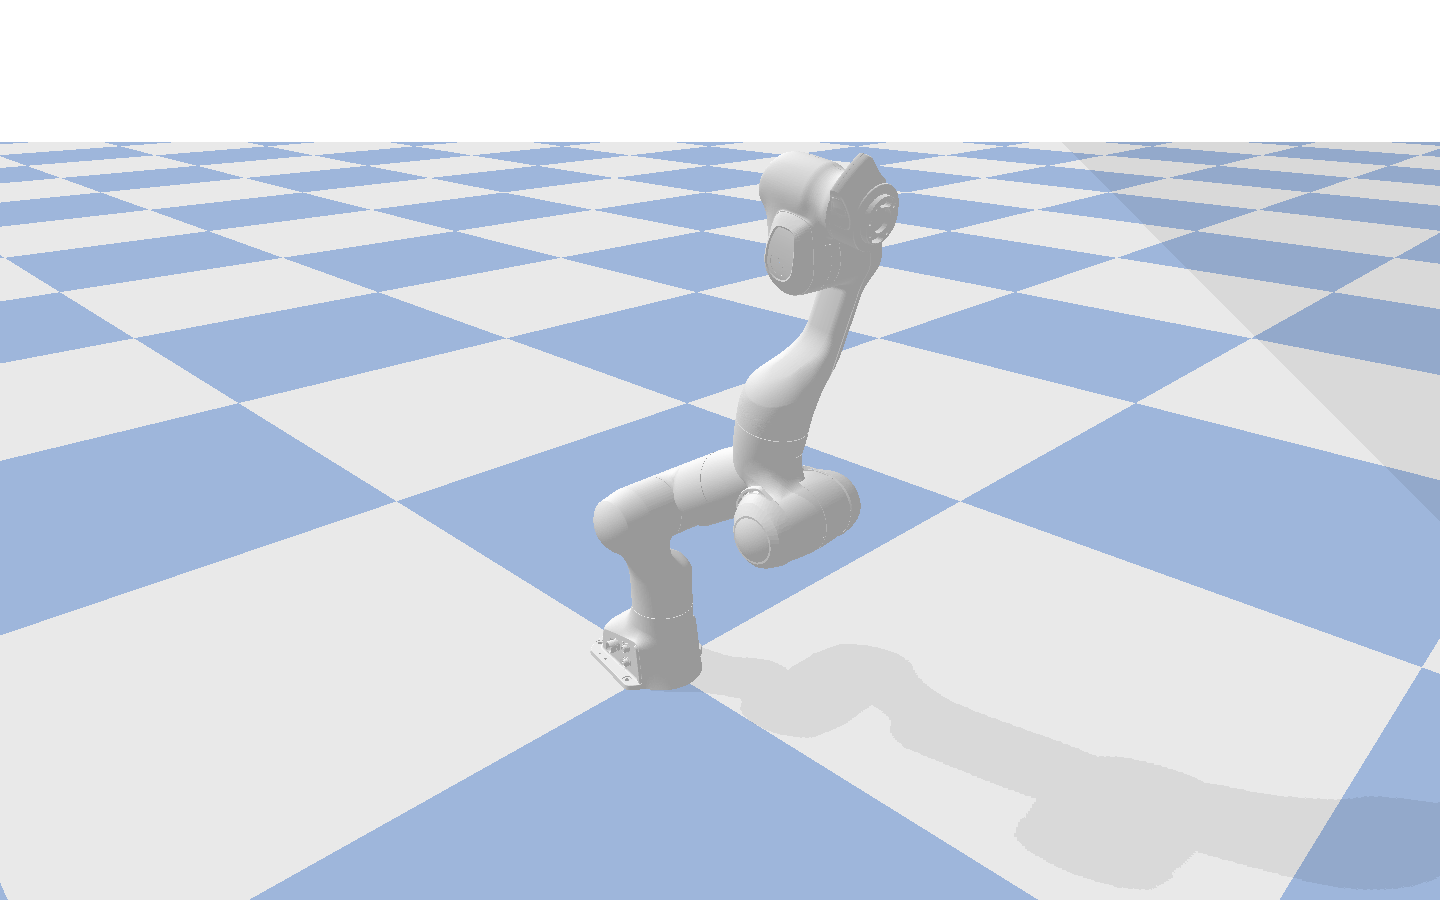
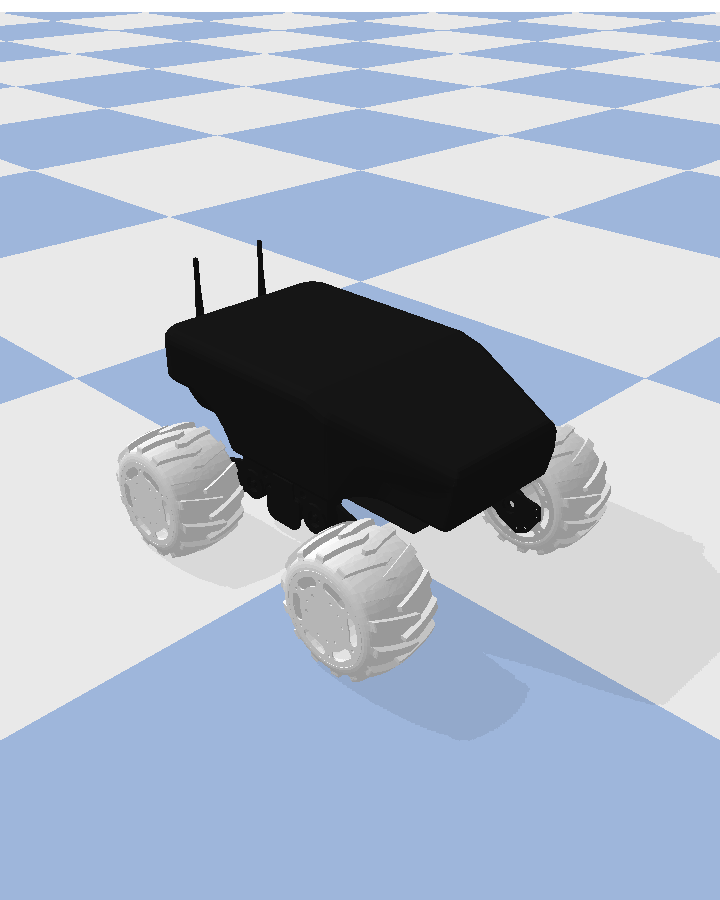
- ModelCAD-based robot model
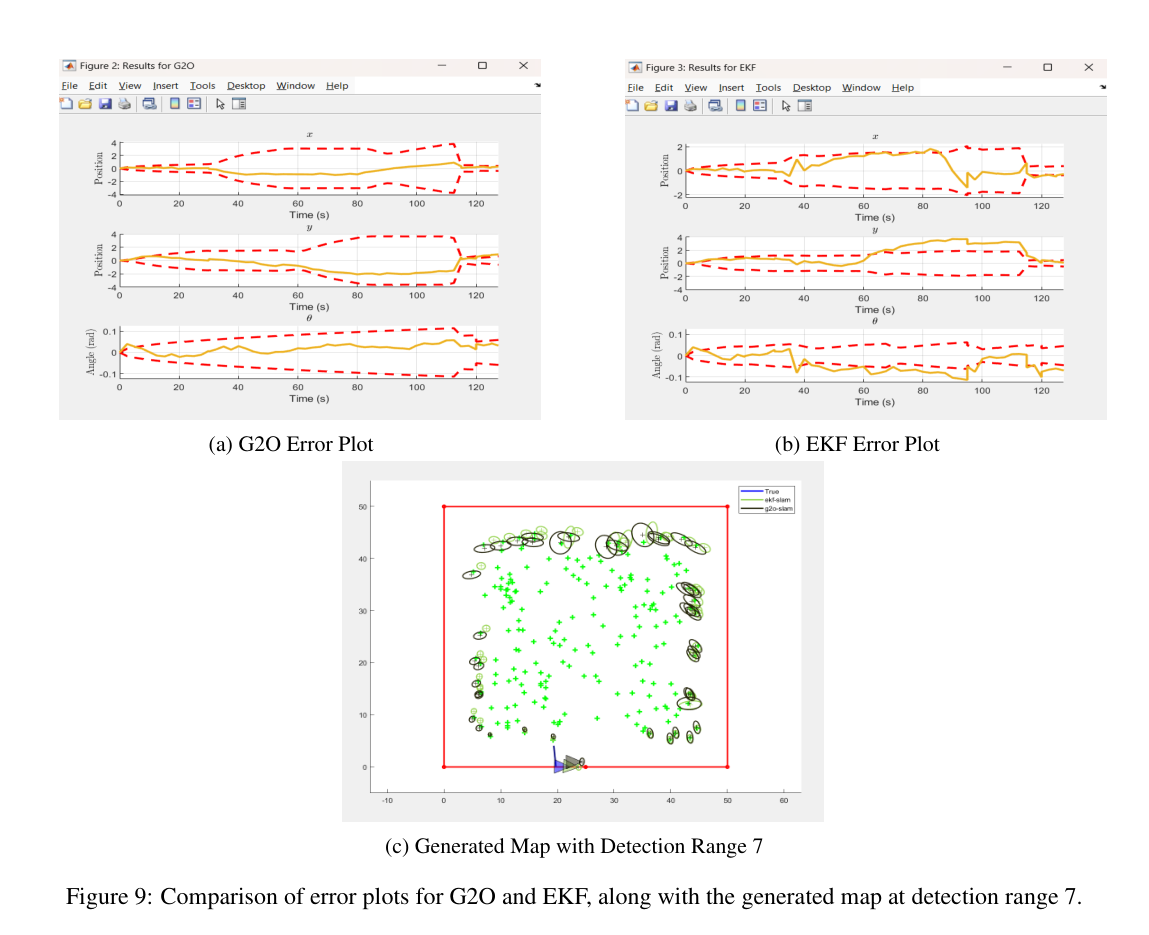
- EstimateUKF state estimation · Sensor-noise tests
- PlanPerceptive NMPC planning interface
- ControlWeighted whole-body QP control
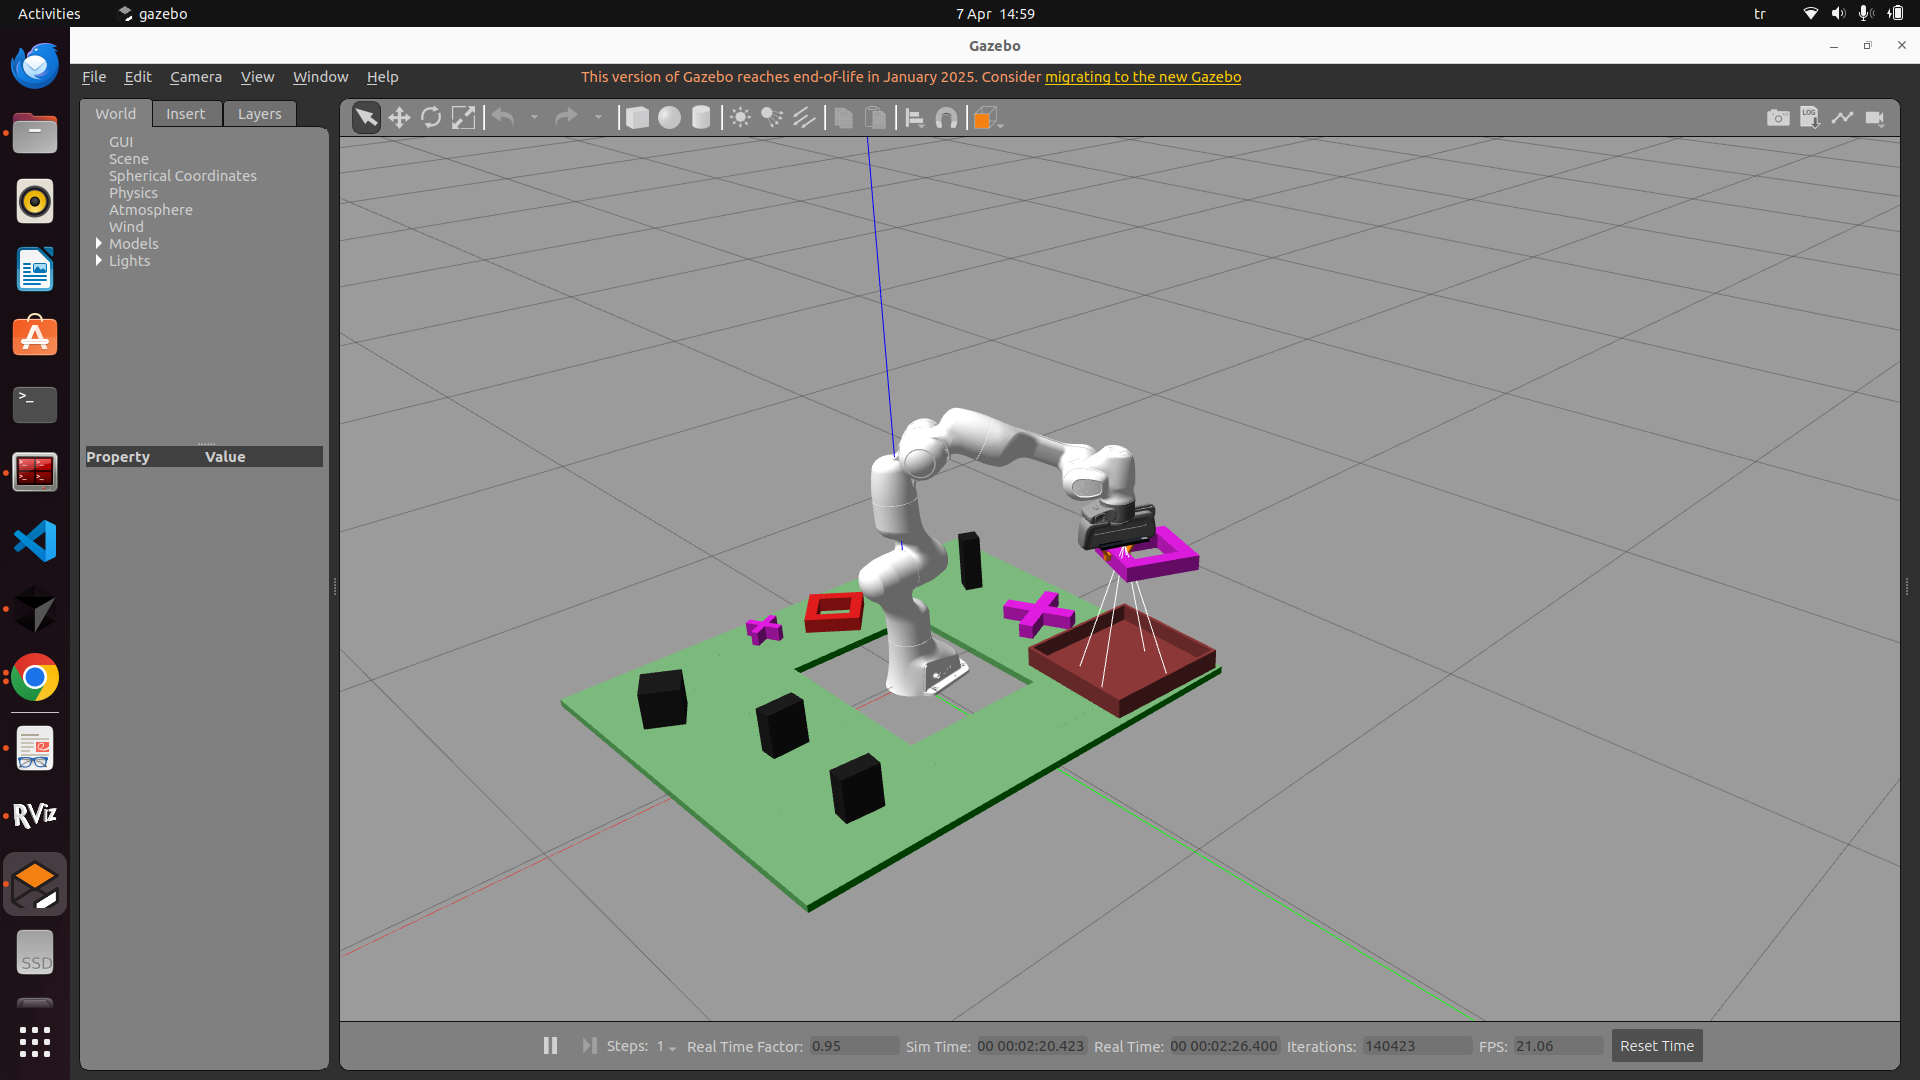
- EvaluateSimulation tests · Physical testing next
Control and validation
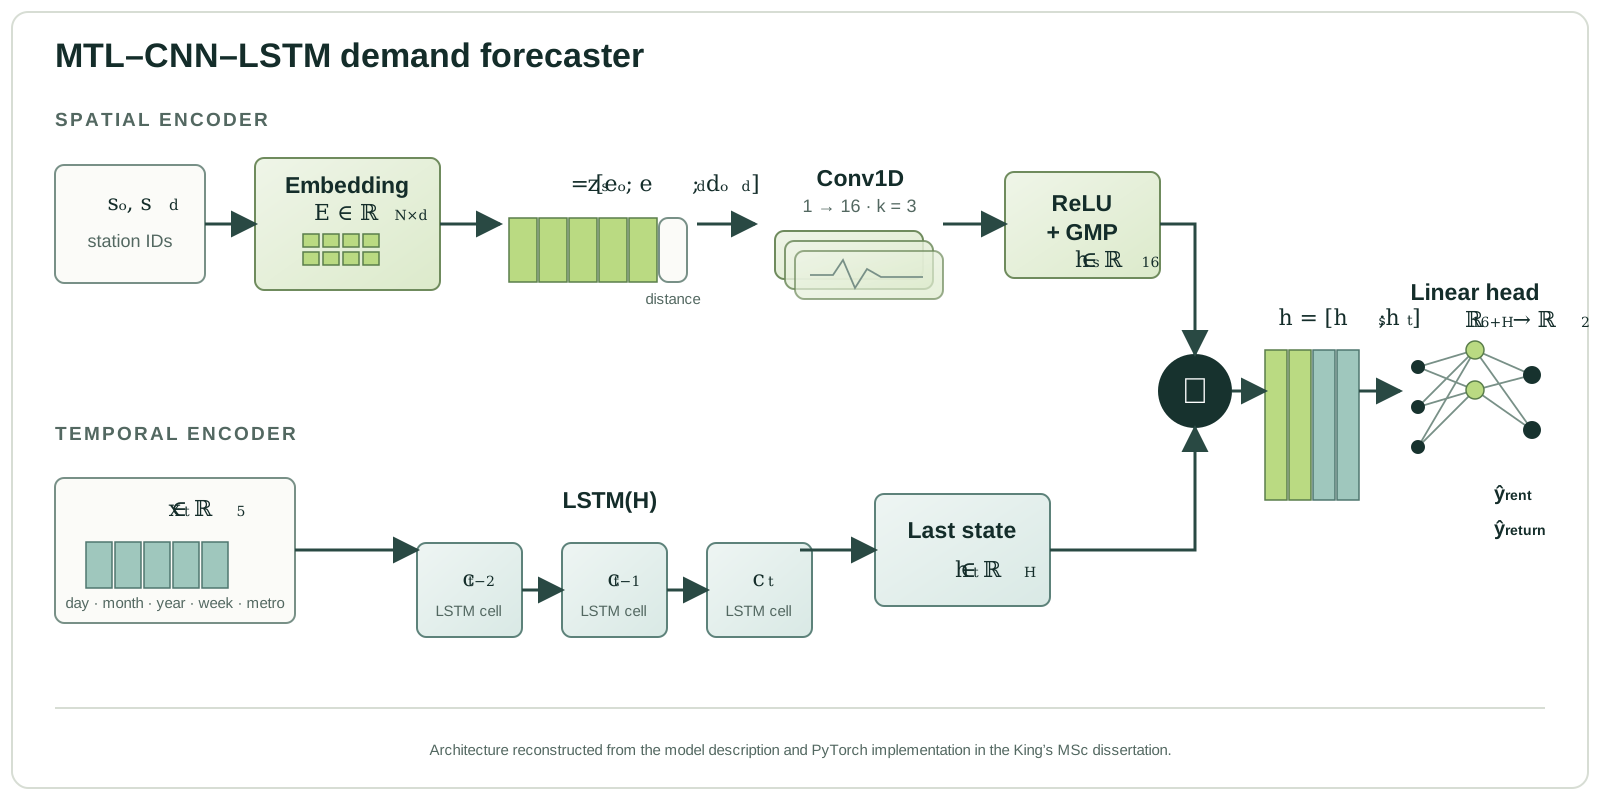
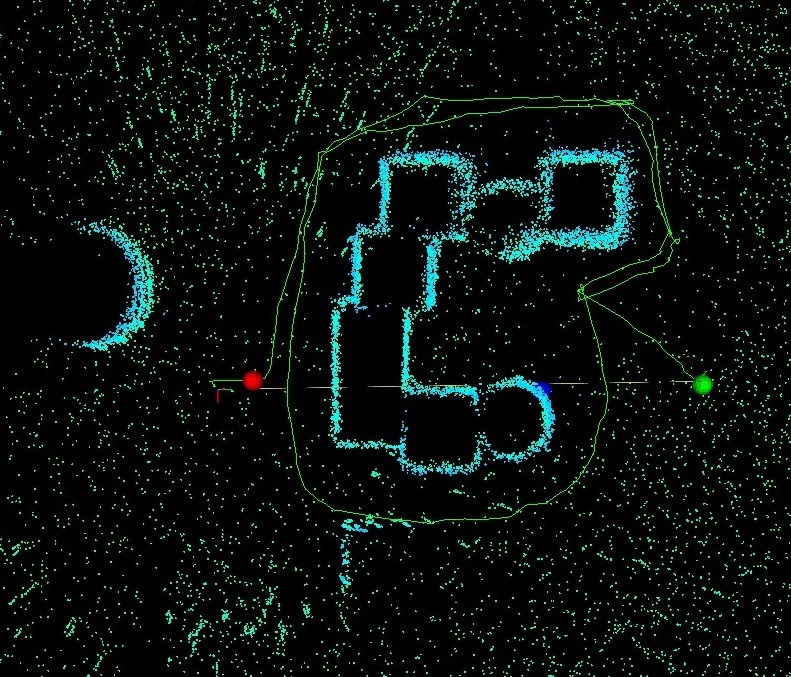
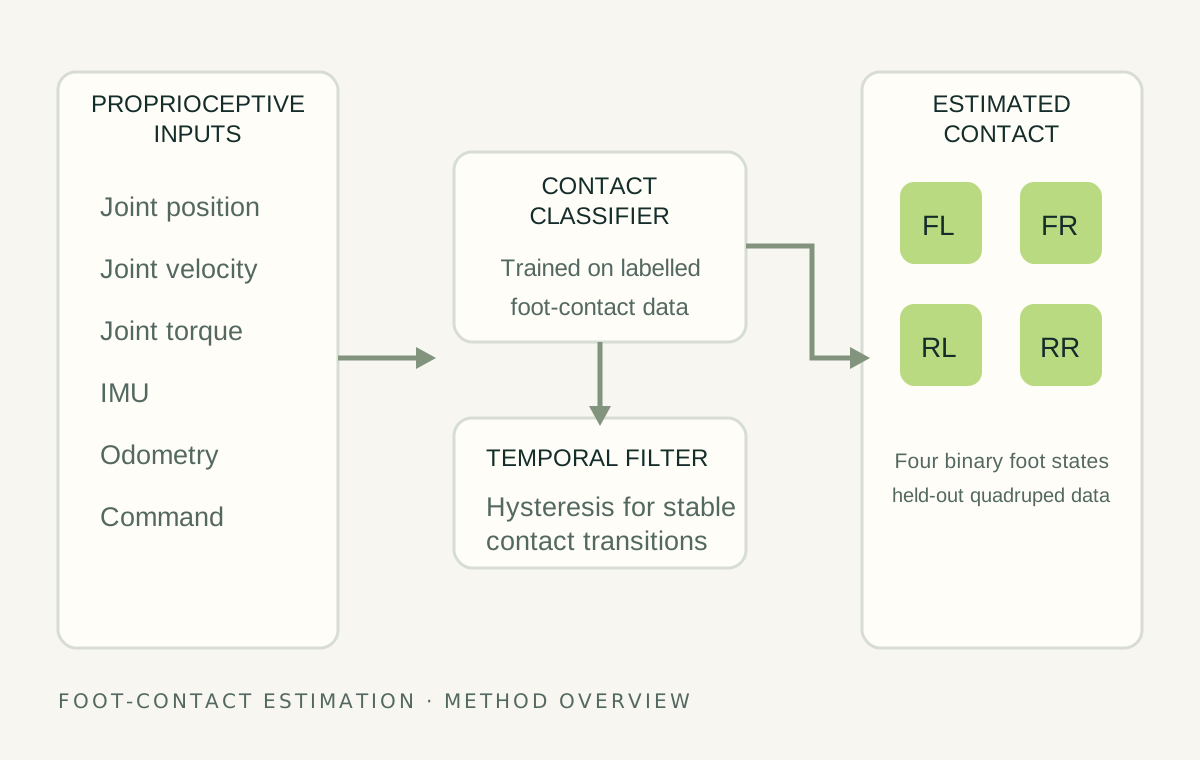
I have tested the simulated system with sensor noise. In earlier quadruped coursework, I also estimated foot-contact states from proprioceptive data and tested cosine, figure-eight and elliptical path tracking. These experiments made contact uncertainty and controller behaviour concrete before I began the independent platform.
The next step is to integrate the hardware, test the controller on the physical robot and then study how learned policies can improve locomotion without losing the structure of the model-based controller.